Chenyu Zhang
S.M. student in Computational Science and Engineering at Harvard University. You can also call me Austin!

Cambridge, MA
I’m an S.M. student in Computational Science and Engineering at Harvard University (GSAS / SEAS). I hold a B.S. in Statistics from the School of Mathematical Sciences at Peking University.
My interests include: Robot Learning, Generative AI, 3D Vision for Robotics, and Computer-Use Agents.
I like building the pieces that let a system be measured honestly — benchmarks, calibration, simulation — and then the models that have to pass those tests. Recently that has meant converting real robot video into physics-consistent simulation, generative models of 3D object-particle dynamics, and long-horizon office workflows for GUI agents.
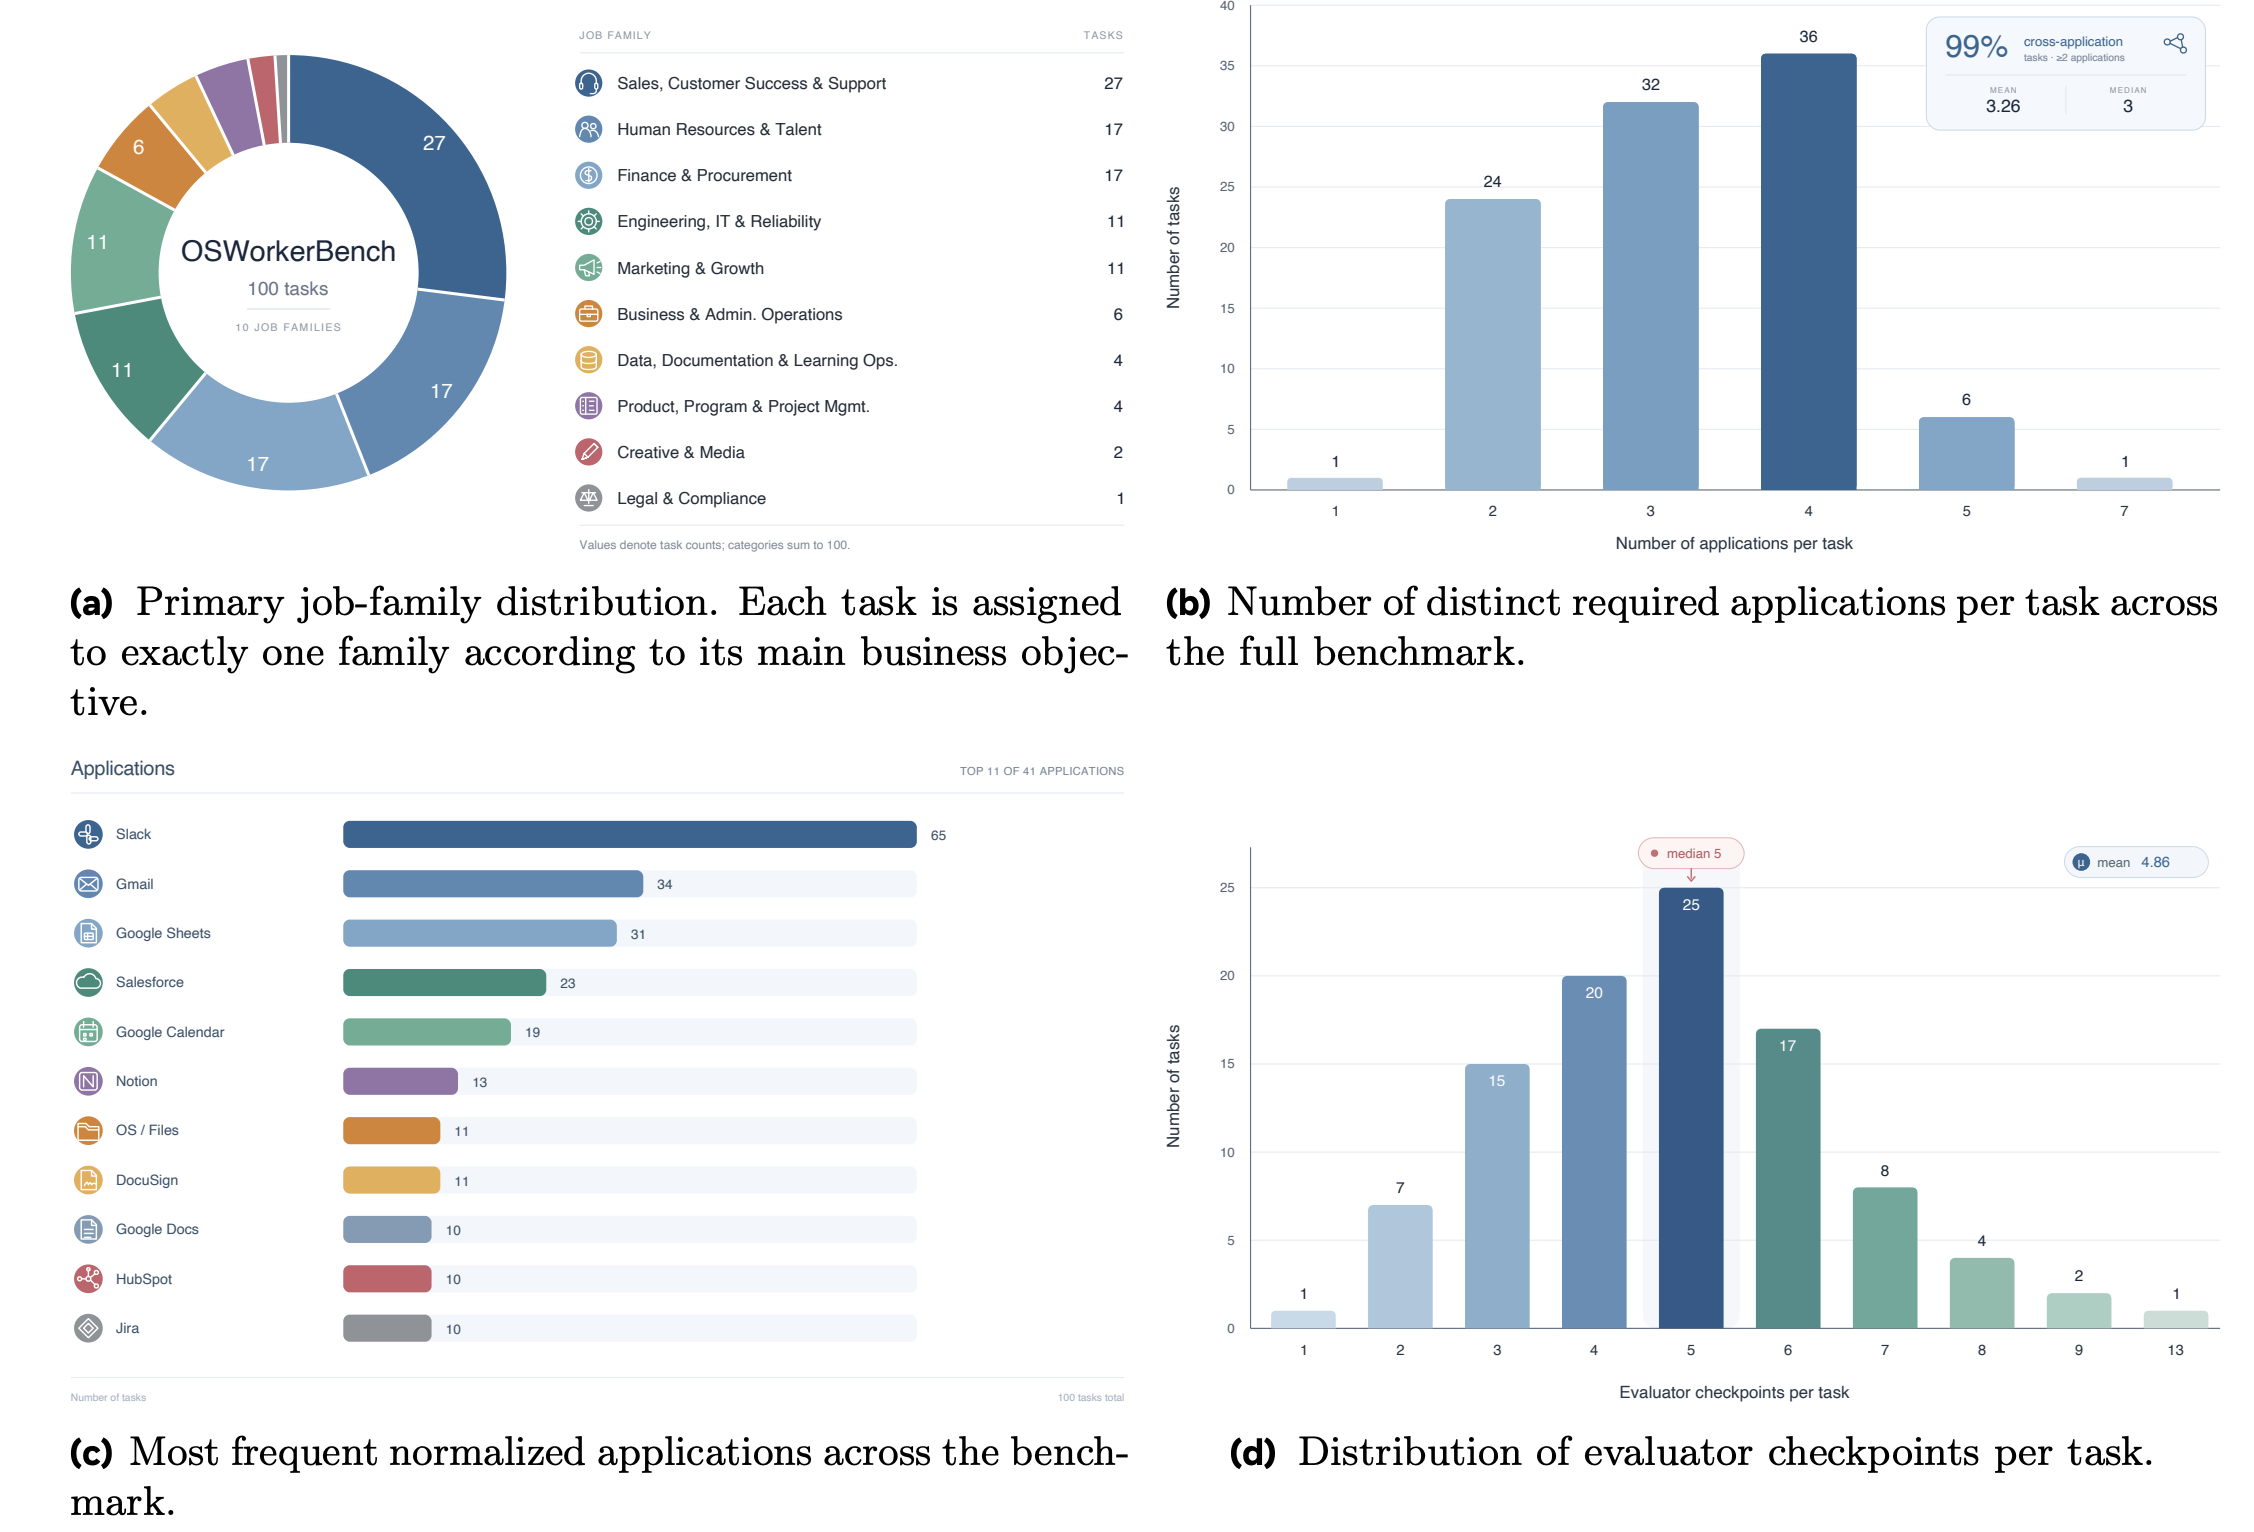
Most recently I was a research intern in the Qingyun Program at Tencent, where I was a core contributor to UI-Mate, the Hy Team’s foundation GUI agent, and owned task construction for its OSWorkerBench benchmark.
Before that, I was a research associate with Dr. Katerina Fragkiadaki in the Machine Learning Department at Carnegie Mellon University, and a research assistant at the OV3 Lab under Dr. Jiahuan Zhou in the Wangxuan Institute of Computer Technology, Peking University.
Away from the screen you’ll usually find me on a tennis or pickleball court, at a piano, or over a chessboard.
news
| Sep 01, 2026 | Started my S.M. in Computational Science and Engineering at Harvard University. Hello, Cambridge! |
|---|---|
| Aug 28, 2026 | UI-Mate is out — Tencent Hy Team’s open-weight foundation GUI agent, released with OSWorkerBench, a benchmark of 100 long-horizon office workflows across 41 applications whose task construction I owned. Code · Report. |
| Jun 30, 2026 | Graduated from Peking University with a B.S. in Statistics from the School of Mathematical Sciences. Four wonderful years — thank you to everyone along the way. |
| Jan 22, 2026 | RobotArena ∞ has been accepted to ICLR 2026! 🎉 |
| Oct 27, 2025 | RobotArena ∞ is on arXiv — scalable robot benchmarking by translating real teleoperation video into simulation. Project page. |
selected publications
- CVPR
 SCAP: Transductive Test-Time Adaptation via Supportive Clique-Based Attribute PromptingIn Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), 2025